sbc · I program this
NVIDIA Jetson Nano
A small GPU board for running vision models at the edge
Project page: Edge AI and robotics
- GPU
- 128-core NVIDIA Maxwell
- CPU
- Quad-core ARM Cortex-A57
- Memory
- 4 GB LPDDR4 on the common model
- I/O
- GPIO, I²C, SPI, UART, CSI camera
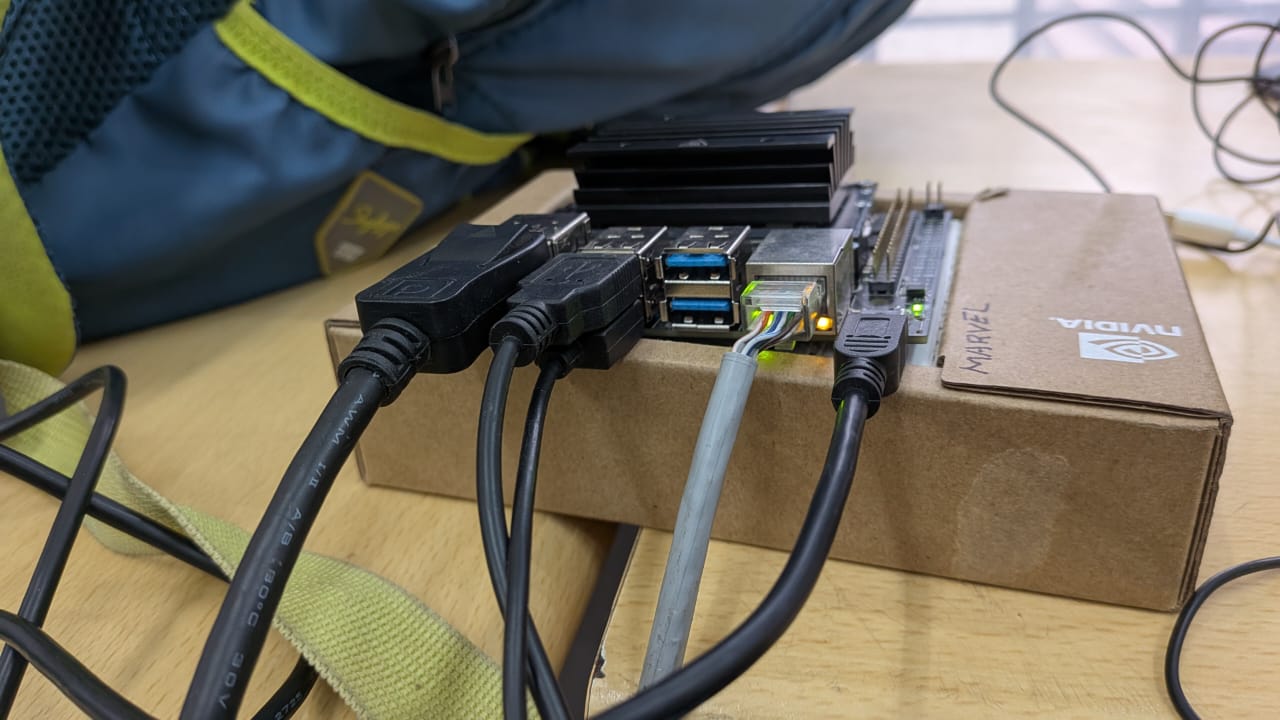
I configured an NVIDIA Jetson Nano from scratch to explore the realities of edge computing. This involved everything from sourcing hardware at a local outlet and flashing the OS with Balena Etcher to managing thermals with an external cooling fan. My primary focus was deploying a real-time object detection pipeline, where I wrote a custom Python wrapper to optimize inference speed directly on the board’s 128-core Maxwell GPU.
To push the hardware limits, I also experimented with running Ollama’s Llama 3.2:3b locally. Although the aging architecture faced memory bottlenecks, the project was a hands-on masterclass in resource optimization and hardware-software integration. It moved AI from the abstraction of a cloud notebook into a physical, power-constrained device.