vrishank

Hi, I'm

Vrishank Aryan S

I build robots, embedded systems and the AI that runs on them.

Intern at Hoogway.aiJoining Dell · June 2027Bangalore, India

Live The arm from my MuJoCo model, rebuilt for the browser. Move your pointer: the tip follows it, and the three readouts are the tendon pulls it takes to get there.

01About meThe short version

I'm a software engineer in Bangalore, studying Information Science at UVCE. I like problems where code has to touch the physical world: a servo that has to move on time, a model that has to fit on a Jetson, a voice agent that has to hold up on a real phone call.

Right now I'm an AI and software engineering intern at Hoogway.ai, working on a production voice-AI pipeline, and I'm joining Dell in June 2027. Outside of work I build robots, train a reinforcement-learning environment on a tendon-driven arm in MuJoCo, and rebuild language-model pieces from scratch to see how they work.

Now
AI and software engineering intern, Hoogway.ai
Next
Joining Dell, June 2027
Studying
Information Science Engineering, UVCE
Based in
Bangalore, India
  • Robotics
  • Embedded systems
  • Edge AI
  • Reinforcement learning
  • Simulation (MuJoCo)
  • Language-model internals
  • Voice AI

The longer story →

02Things that moveBuilds, experiments and half-answers

Robotics MuJoCo simulation and RL environment · personal project

SpiRobs In progress

A 3D simulation in MuJoCo of a tendon-driven robotic arm: three tendons, three actuators. I'm training a reinforcement-learning environment on it, and training is going well.

Simulator
MuJoCo, 3D
Arm
Three tendons
Actuation
3 actuators
Learning
Reinforcement-learning environment, training in progress

Hardware Voice-controlled robot · personal build

Sesame Built

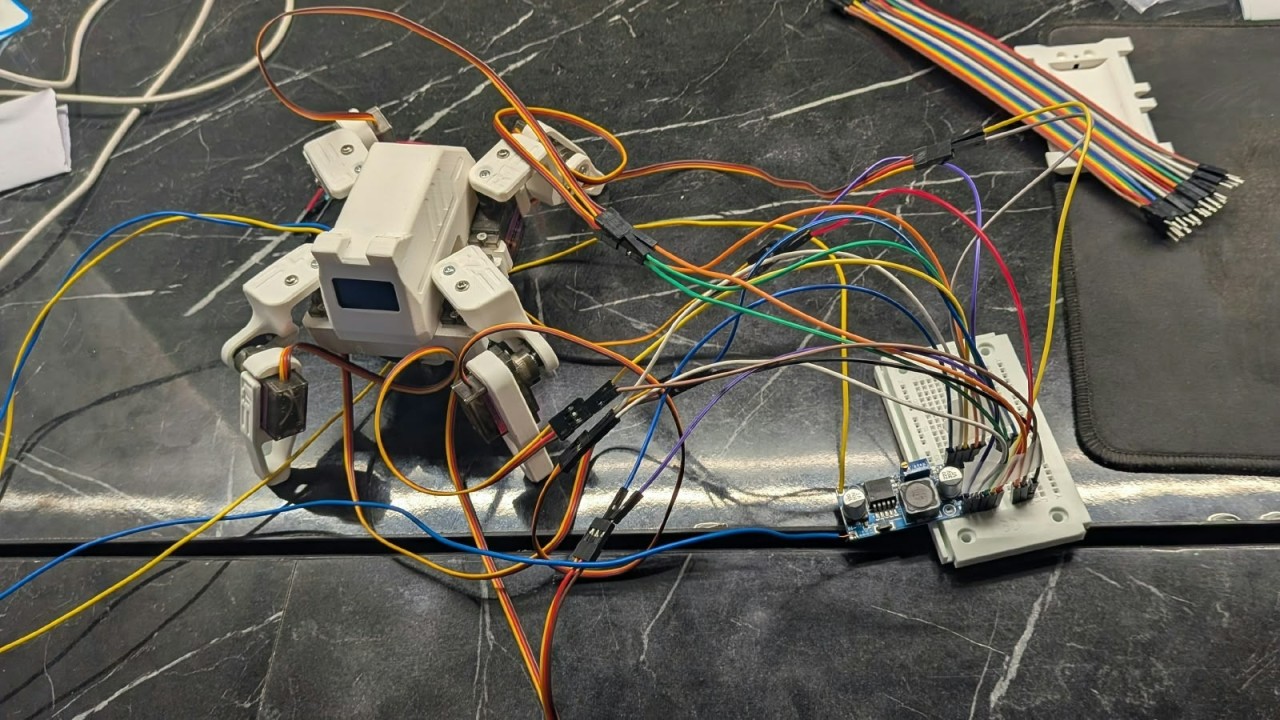
Sesame is an open-source conversational robot designed by Dorian Todd. I rebuilt it on my own electronics instead of the original PCB, then wrote the firmware that ties everything together.

A single ESP32 handles the microphone, speaker, display and eight servos. It listens for voice commands, talks back and moves in response. I also edited the enclosure's top-cover STL so the new electronics fit.

ESP32-WROOM-32SSD1306 OLEDPCA9685UBEC regulator

Controller
ESP32-WROOM, custom firmware
Display
SSD1306 OLED over I²C
Actuation
PCA9685 PWM driver, 8 micro servos
Power
UBEC regulated supply
Audio
Microphone and speaker, hands-free voice I/O
Enclosure
Modified STL top cover

Hardware On-device perception · personal project

Edge AI and robotics Built

Real-time object detection running on-device, where compute is tight. An ESP32 turns the model's output into physical action, so the robot sees something and reacts to it.

Raspberry Pi 5NVIDIA Jetson Nano

Compute
NVIDIA Jetson Nano, Raspberry Pi 5
Control
ESP32 bridging model output to actuators
Task
Real-time object detection, on-device
Loop
Perception to actuation, closed

Hardware Autonomous drone · ISRO Robotics Hackathon

Mars Surface Survey UAV Competition

A drone built for an ISRO-organized hackathon that simulated autonomous surveying of the Martian surface. I worked on software and electronics subsystems and on integrating them on the aerial platform under competition constraints.

Platform
Unmanned aerial vehicle
Mission
Simulated autonomous Mars surface survey
My part
Software and electronics subsystems, integration
Event
ISRO Robotics Hackathon

Built from scratch, to see how it works

  1. 01GPT-2 transformerA mini GPT-2 written from the ground up: custom tokenizer, token and positional embeddings, causal multi-head self-attention, residual feed-forward layers and autoregressive generation. Trained on Tiny Shakespeare.AI / ML
  2. 02BPE tokenizerThe cl100k_base tokenizer used by GPT-4, reimplemented from scratch: subword tokenization, merge rules and vocabulary construction.AI / ML
  3. 03Word2VecWord embeddings built without a framework, capturing semantic relationships as the base for similarity and analogy tasks.AI / ML
  4. 04BrainCellsA neural network built using only raw PyTorch tensors: no torch.nn, no autograd. Forward pass, activations, loss, backprop and weight updates all written by hand.AI / ML
  5. 05Naive Bayes spam classifierA spam classifier from scratch using word frequencies and Bayes’ theorem, with no ML libraries.AI / ML
  6. 06From-scratch implementationsPerceptron, softmax regression, Gaussian discriminant analysis and SGD, written with only NumPy and the math, a repo I keep adding to.AI / ML

All projects →

Say hello.

Internships, projects and odd hardware ideas are all welcome.